DataObjectFilters.resample_to_image#
- DataObjectFilters.resample_to_image(
- *,
- reference_volume: ImageData | None = None,
- dimensions: VectorLikeInt | None = None,
- spacing: float | VectorLikeFloat | None = None,
- target_n_points: int | None = None,
- max_n_points: int | None = None,
- rounding_func: Callable[[VectorLikeFloat], VectorLikeInt] | None = None,
- cell_length_percentile: float | None = None,
- cell_length_sample_size: int | None = None,
- method: Literal['sample', 'interpolate'] | None = None,
- null_value: float | None = None,
- mark_blank: bool = False,
- tolerance: float | None = None,
- categorical: bool | None = None,
- radius: float | None = None,
- sharpness: float | None = None,
- progress_bar: bool = False,
Resample this mesh’s arrays onto a uniform grid.
The mesh’s arrays are resampled at the points of a new
ImageData. Each point is the center of a voxel, and the voxels tile the input’s bounds, so the image’s points are inset half a spacing from those bounds. This is a one-line alternative to building the grid explicitly and callingsample()orinterpolate()on it.The output geometry can be controlled in several ways:
Specify the output geometry using a
reference_volume.Specify the
spacingexplicitly.Specify the
dimensionsexplicitly.Specify the
target_n_points. The spacing is isotropic and estimated so the output has approximately this many points.Specify the
cell_length_percentile. The spacing is estimated from the mesh’s cells using the specified percentile.
Set
max_n_pointsto cap the result of any of these. It differs fromtarget_n_points, which is a resolution to aim for: a geometry specified explicitly raises if it exceeds the cap, while an estimated one is coarsened to fit.Use
reference_volumefor full control of the output’s geometry. For all other options, the geometry is implicitly defined such that the generated voxels fit the bounds of the input mesh.If no inputs are provided,
cell_length_percentile=0.1(tenth percentile) is used by default to estimate the spacing, so the input’s own cells set the resolution.The values are resampled with one of two methods, chosen by
method:'sample'interpolates inside the input’s cells, and is the default for an input with volumetric cells. It is the only method which uses the input’s topology, and the only one which reads its cell data. It keeps the voxels whose centre lies inside a cell, so the result stops just inside a volumetric mesh’s surface.'interpolate'interpolates from the input’s points withinradius, and is the default otherwise, since a cell search misses most of a curved surface and all of a point cloud. It reads point data only. By defaultradiusreaches across the input’s cells, so every voxel a cell crosses is filled and the result straddles the input.
Both write to the output’s point data, and resampling a solid therefore fills different voxels than resampling its surface.
A flat input is the exception: its voxels are centered on it, so
'sample'reaches every one of them and reproduces the values exactly.Added in version 0.50.
Note
Voxels with no value are flagged with a
'vtkValidPointMask'point data array. Setmark_blank=Trueto also hide them with a'vtkGhostType'array, so volume rendering the output shows those regions as transparent.Note
A
MultiBlockis resampled as a whole: one grid covers every block, a voxel takes its value from whichever block reaches it, and only the arrays every block has are kept. Themethodis chosen for the composite as a whole, so a surface among solids needsmethod='interpolate'to be filled.- Parameters:
- reference_volume
ImageData, optional Volume to use as a reference. The output will have the same
dimensions,origin,spacing,offset, anddirection_matrixas the reference. Only this geometry is taken from it; its arrays are not read.- dimensions
VectorLikeInt, optional Dimensions of the generated image. Set this value to control the dimensions explicitly. If unset, the dimensions are defined implicitly through other parameters. See summary and examples for details.
- spacing
float|VectorLikeFloat, optional Approximate spacing to use for the generated image. Set this value to control the spacing explicitly. If unset, the spacing is defined implicitly through other parameters. See summary and examples for details.
- target_n_points
int, optional Approximate number of points to generate. The spacing is isotropic and chosen so the output holds about this many points, distributed between the axes in proportion to the input’s bounds. An axis with no extent holds a single point and takes no part in the count. Rounding to whole voxels means the count is approached, not matched exactly. Cannot be set with
reference_volume,dimensions,spacing, or the cell length options.- max_n_points
int, optional Strict upper bound on the number of points generated. Unlike
target_n_points, which is only approached, this limit is never exceeded. How it is enforced depends on how the geometry is defined:Geometry set explicitly, with
reference_volume,dimensions,spacingor a cell length option, raises if it exceeds the limit.target_n_pointsmust not exceed the limit, and the grid estimated from it is coarsened if rounding would take it above.Geometry left to the defaults is coarsened to fit, without raising.
- rounding_func
Callable[VectorLikeFloat,VectorLikeInt], optional Control how the dimensions are rounded to integers based on the provided or calculated
spacing. Should accept a length-3 vector containing the dimension values along the three directions and return a length-3 vector.numpy.round()is used by default.Rounding the dimensions implies rounding the actual spacing.
Cannot be set together with
reference_volumeordimensions.- cell_length_percentile
float, optional Cell length percentage
pto use for computing the defaultspacing. Default is0.1(tenth percentile) and must be between0and1. Thep-th percentile is computed from the lengths of the edges of the mesh’s own cells, with every block of a composite included. Up tocell_length_sample_sizecells are used, drawn at random with a fixed seed, and degenerate edges with zero length are ignored.The estimate is a single value which is used for all three axes, so an anisotropic input is resampled below its native spacing along its coarsest axis.
Has no effect if
dimensionsorreference_volumeare specified.- cell_length_sample_size
int, optional Maximum number of cells to use when computing the
cell_length_percentile.100 000cells are used by default.- method‘sample’ | ‘interpolate’, optional
Method used to compute each voxel’s value.
'sample'interpolates inside the input’s cells, and'interpolate'interpolates from its points withinradius. By default'sample'is used for an input with volumetric cells and'interpolate'is used otherwise. See summary for details.'interpolate'reads point data only, so the input’s cell data is dropped and a warning is raised. Callcell_data_to_point_data()on the input to keep it. It writes every array asfloat32, so an integer array comes back as floats.- null_value
float, optional Value given to the voxels which no value could be resampled for. Every array of the output takes it, and zero is used by default. Both methods accept it, though only
method='interpolate'has it natively; undermethod='sample'this filter fills the voxels itself, and the value must fit the data type of the arrays it fills.- mark_blankbool, default:
False Hide the voxels which no value could be resampled for, by flagging them in a
'vtkGhostType'array. These are the voxels holdingnull_value. Every voxel is visible by default, and the blank ones can be filtered with the'vtkValidPointMask'array instead.- tolerance
float, optional Requires
method='sample', and is forwarded tosample(). Tolerance used when locating the cell a voxel is sampled from. The tolerance computed by vtkResampleWithDataSet is used by default.- categoricalbool, optional
Requires
method='sample', and is forwarded tosample(). Control whether the source point data is to be treated as categorical. IfTrue, the resampled point data will be determined by a nearest neighbor interpolation scheme.Falseby default.- radius
float, optional Requires
method='interpolate', and is forwarded tointerpolate(). Distance from a voxel’s center within which the input’s points contribute to it. By default it is the 95th percentile of the length of the input’s cell edges, so that a cell’s points reach every voxel the cell crosses, and never less than half a voxel’s diagonal, which is what a point cloud gets.- sharpness
float, optional Requires
method='interpolate', and is forwarded tointerpolate(). Sharpness of the Gaussian interpolation kernel,2.0by default. As this value increases, the weights of points far from a voxel’s center fall off faster.- progress_barbool, default:
False Display a progress bar to indicate progress.
- reference_volume
- Returns:
ImageDataUniform grid with the input’s arrays sampled onto its points. The voxels are points, not
VOXELcells;points_to_cells()converts them and carries the blanking over. See Image Data Representations for the difference.
Examples#
Download Python source code | Download Jupyter notebook
Resample a solid sphere’s point data onto a uniform grid. The spacing is estimated from the mesh’s own cells.
>>> import pyvista as pv
>>> solid_sphere = pv.SolidSphere()
>>> solid_sphere['height'] = solid_sphere.points[:, 2]
>>> volume = solid_sphere.resample_to_image()
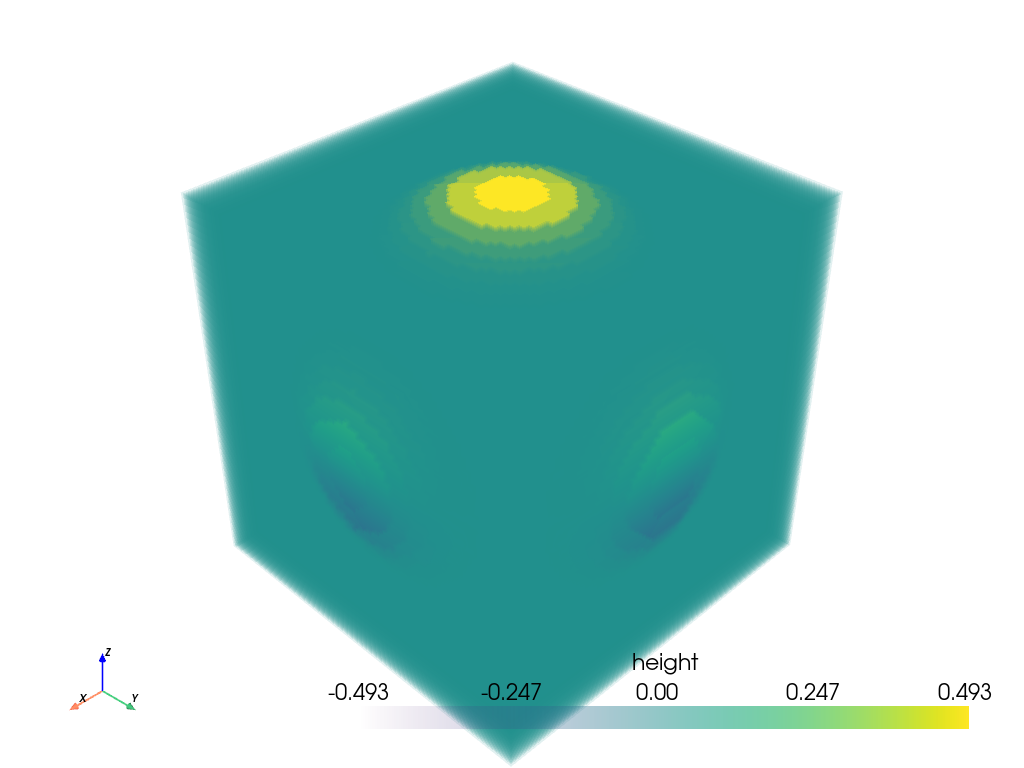
Volume render the result. Every voxel is visible, so the volume is a solid block.
>>> volume.plot(volume=True)
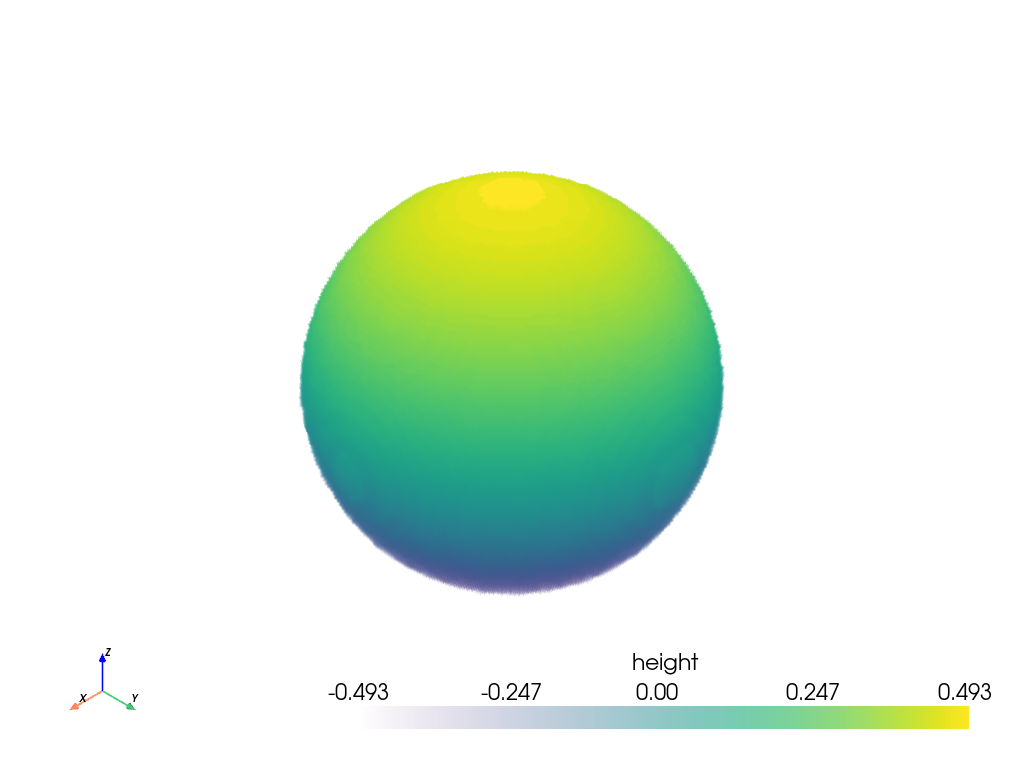
Set mark_blank=True to hide the voxels no value could be resampled for.
>>> blanked = solid_sphere.resample_to_image(mark_blank=True)
>>> blanked.plot(volume=True)
Set the dimensions or the spacing to control the resolution explicitly.
>>> solid_sphere.resample_to_image(spacing=0.05).dimensions
(20, 20, 20)
Compare the three kinds of input the sphere can be given as: a solid, the surface enclosing it, and its points alone.
>>> def resample_as_voxels(mesh):
...     image = mesh.resample_to_image(spacing=0.05, mark_blank=True)
...     return image.points_to_cells()
>>> surface = solid_sphere.extract_surface(algorithm=None)
>>> pointset = solid_sphere.cast_to_pointset()
>>> datasets = {
...     'solid': solid_sphere,
...     'solid voxels': resample_as_voxels(solid_sphere),
...     'surface': surface,
...     'surface voxels': resample_as_voxels(surface),
...     'pointset': pointset,
...     'pointset voxels': resample_as_voxels(pointset),
... }
>>> pv.plot_compare(datasets, shape=(3, 2), scalars='height')
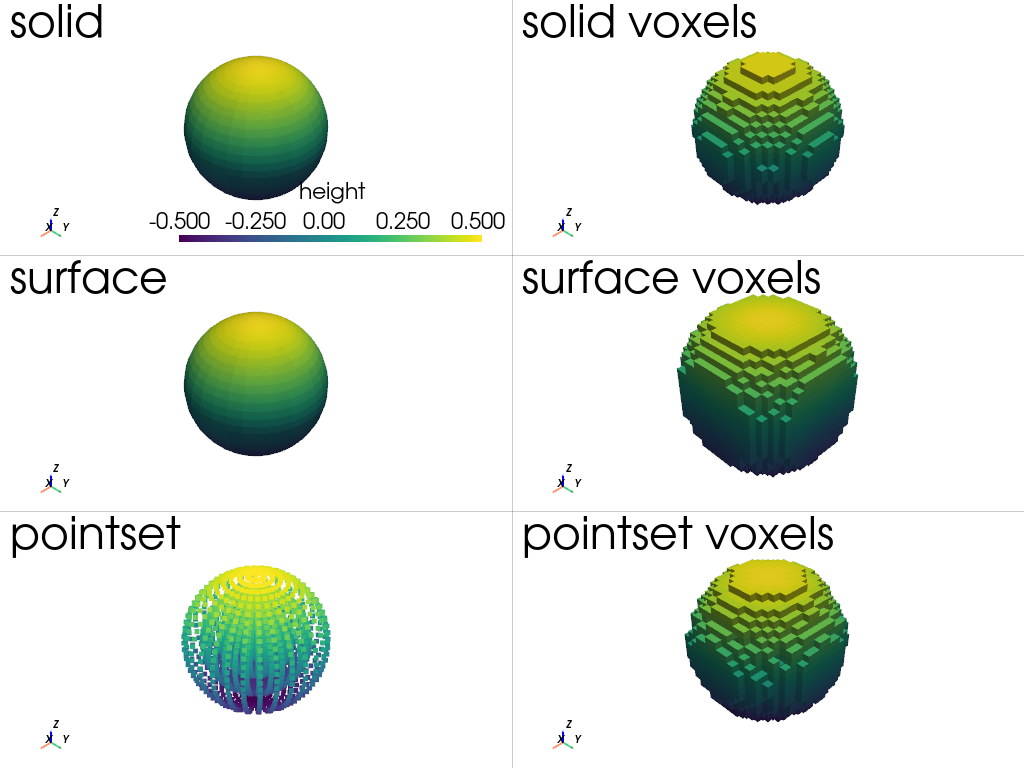
The solid is filled throughout, and the surface fills only the shell its cells
occupy. The point cloud keeps the solid’s interior points, so it reaches the
interior too, but only within radius of each point, which leaves gaps where
the points are sparse.
Resample every block of a MultiBlock onto one grid.
>>> blocks = pv.MultiBlock([pv.Sphere(), pv.Sphere(center=(1.5, 0, 0))])
>>> for block in blocks:
...     block['height'] = block.points[:, 2]
>>> blocks.resample_to_image(target_n_points=20_000).dimensions
(50, 20, 20)
See Also#
pyvista.DataObjectFilters.sampleFilter used by
method='sample'. Samples onto an existing mesh of any type, and exposes options this one does not.pyvista.DataSetFilters.interpolateFilter used by
method='interpolate'. Interpolates onto an existing mesh of any type, and exposes options this one does not.pyvista.ImageDataFilters.resampleChange the dimensions or spacing of an image which is already
ImageData.pyvista.DataSetFilters.voxelize_binary_maskVoxelize the inside of a closed surface as a mask. Operates on a surface’s geometry and generates a new array instead of resampling existing ones. It places its voxels identically to this filter, and keeps essentially the same voxels that
method='sample'keeps for the solid a surface encloses.pyvista.create_gridCreate a uniform grid surrounding a dataset. Its points lie on the dataset’s bounds, whereas this filter’s voxels fit them.
Used In#
Gallery Examples